Suspension geometry
Develop the mechanical layout to support stable, controlled pod movement.
A suspension system designed, manufactured, and tested for a high-speed Hyperloop pod — with a focus on controlled motion and measurable response.
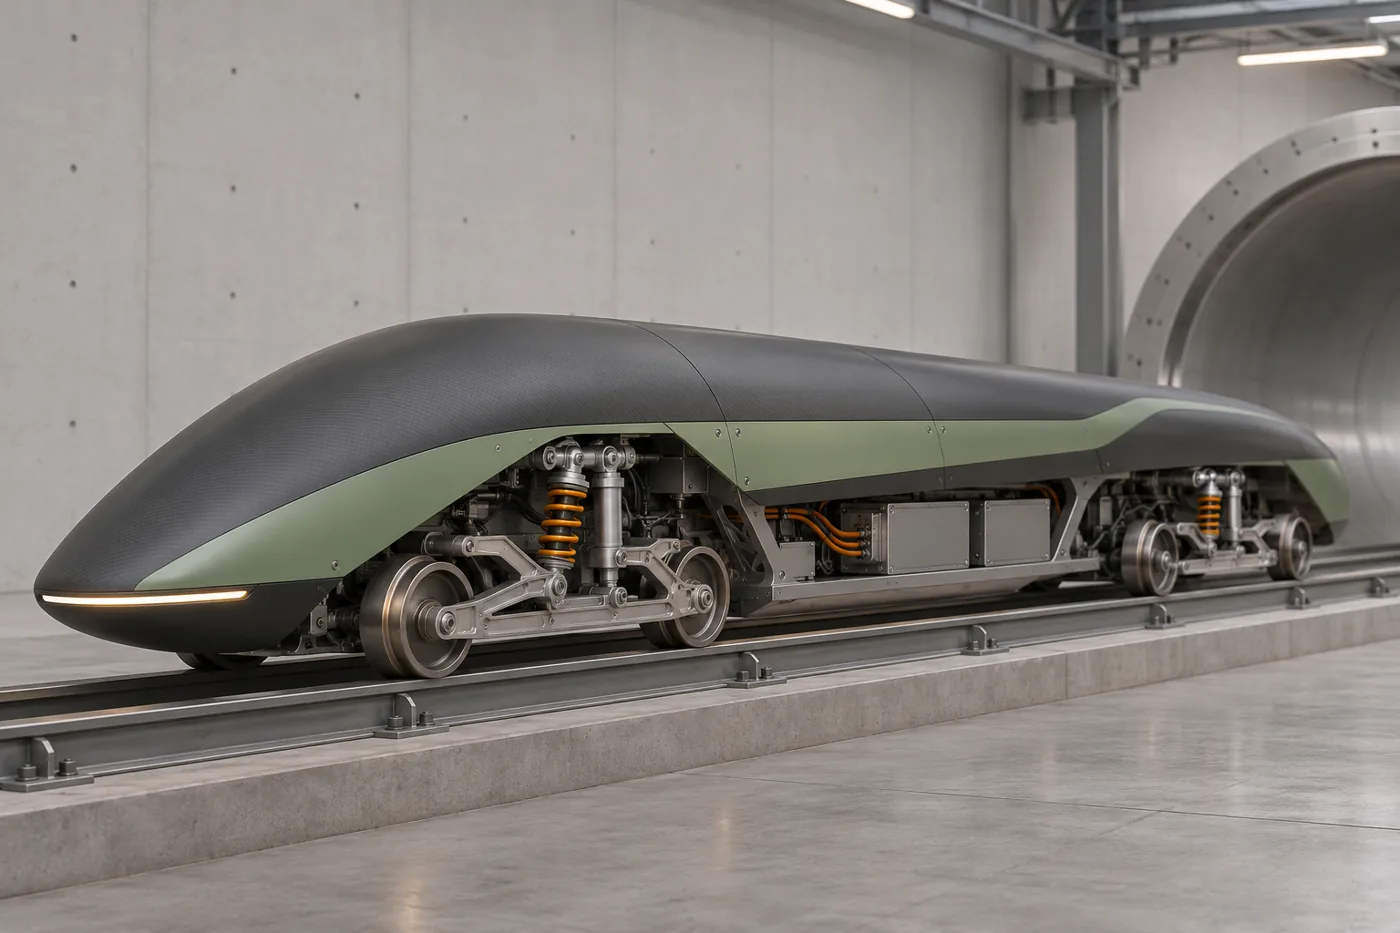
As part of the Avishkar Hyperloop stability and suspension team, I worked on the suspension system for the team’s pod. The goal was to optimize controlled motion at higher speeds through design, manufacturing, and testing.
The team explored semi-active suspension technology and developed a novel test setup to examine the pod’s 7-degree-of-freedom response. These tests helped us evaluate how the system behaved under simulated conditions.
Pod 4.0 combined multiple subsystems. At European Hyperloop Week 2021, the team received the Most Scalable Design Award from Zeleros and ranked fifth for complete pod design.
Change the track input and damping to see how the pod and bogie move relative to each other.
This visual demo illustrates the relationship between track disturbance and body movement. It is not measured project data or a full 7-DOF physics simulation.
Develop the mechanical layout to support stable, controlled pod movement.
Translate the suspension concept into a working assembly for evaluation.
Build a test setup to study the 7-DOF system response and tune the design.
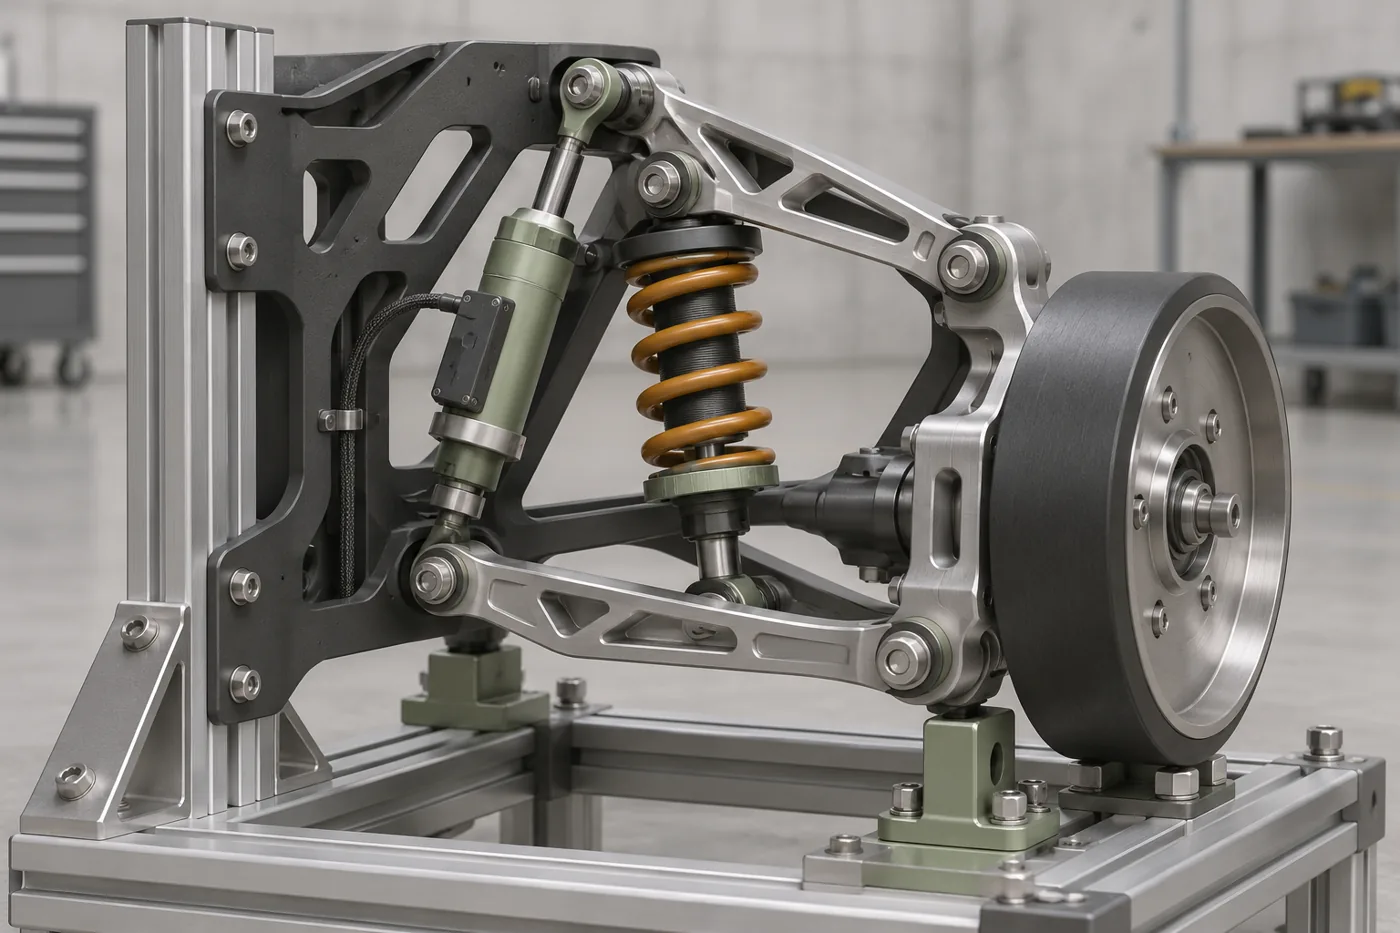
These are concept illustrations created for this portfolio page; they are not photographs or CAD exports of the original team hardware.