Compact quadrotor
A low-cost aerial platform for practical imaging and monitoring applications.
A low-cost semi-autonomous quadrotor for aerial photography, monitoring, and GPS mapping — with a lightweight, 3D-printed camera gimbal.
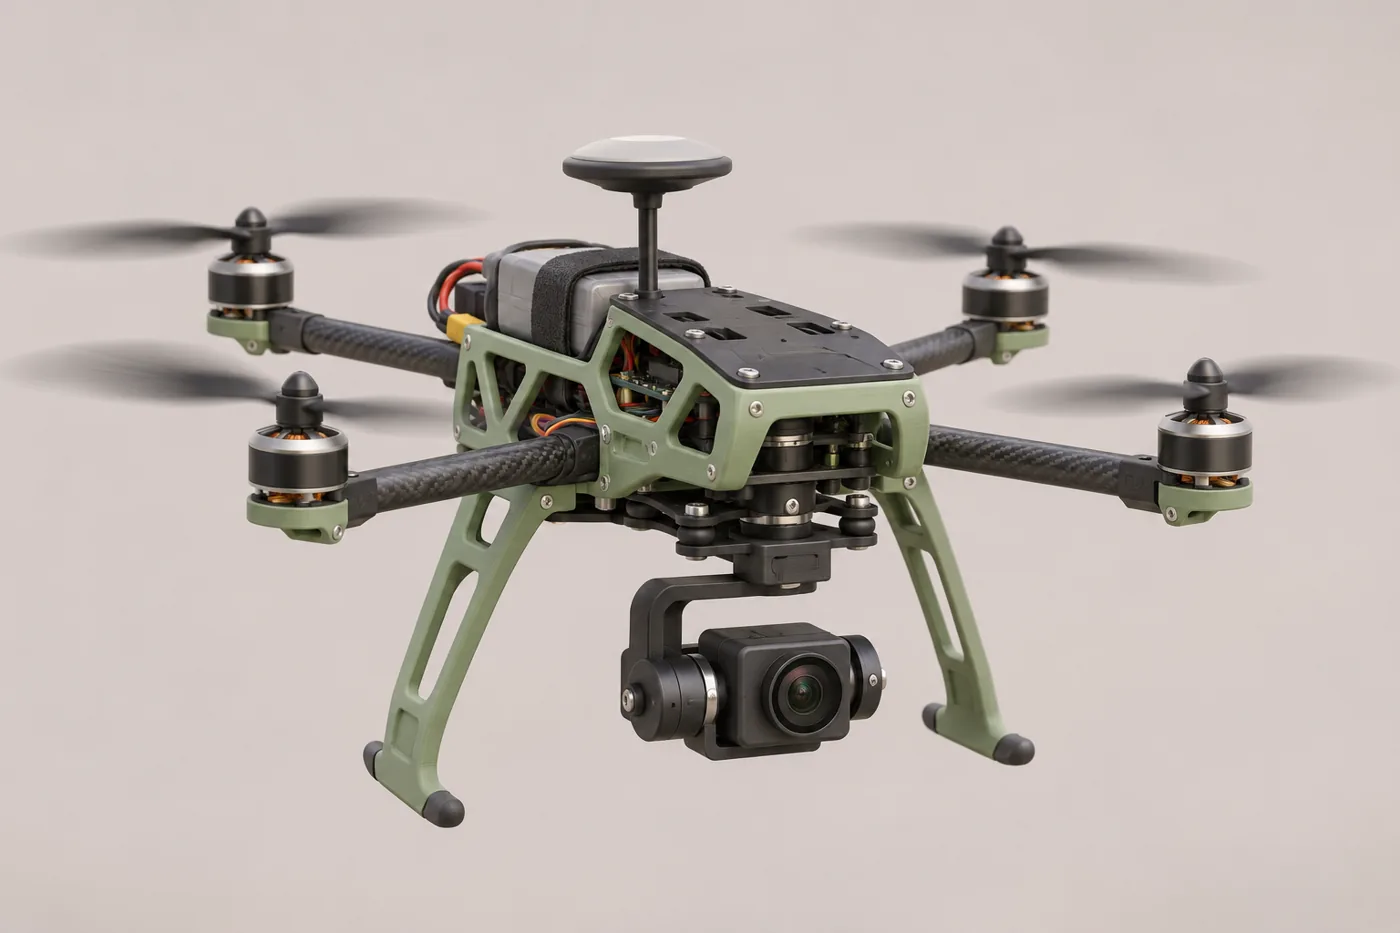
Selfie-copter was a low-cost, semi-autonomous quadrotor developed for aerial photography, monitoring, and GPS mapping.
The system incorporated a 3D-printed two-axis gimbal to reduce cost and weight. We tested the quadrotor in both manual and semi-autonomous operating modes, then optimized the control system based on those tests.
A low-cost aerial platform for practical imaging and monitoring applications.
A lightweight, 3D-printed mount to stabilize the camera while keeping mass down.
Evaluate manual and semi-autonomous modes, then optimize system behavior.
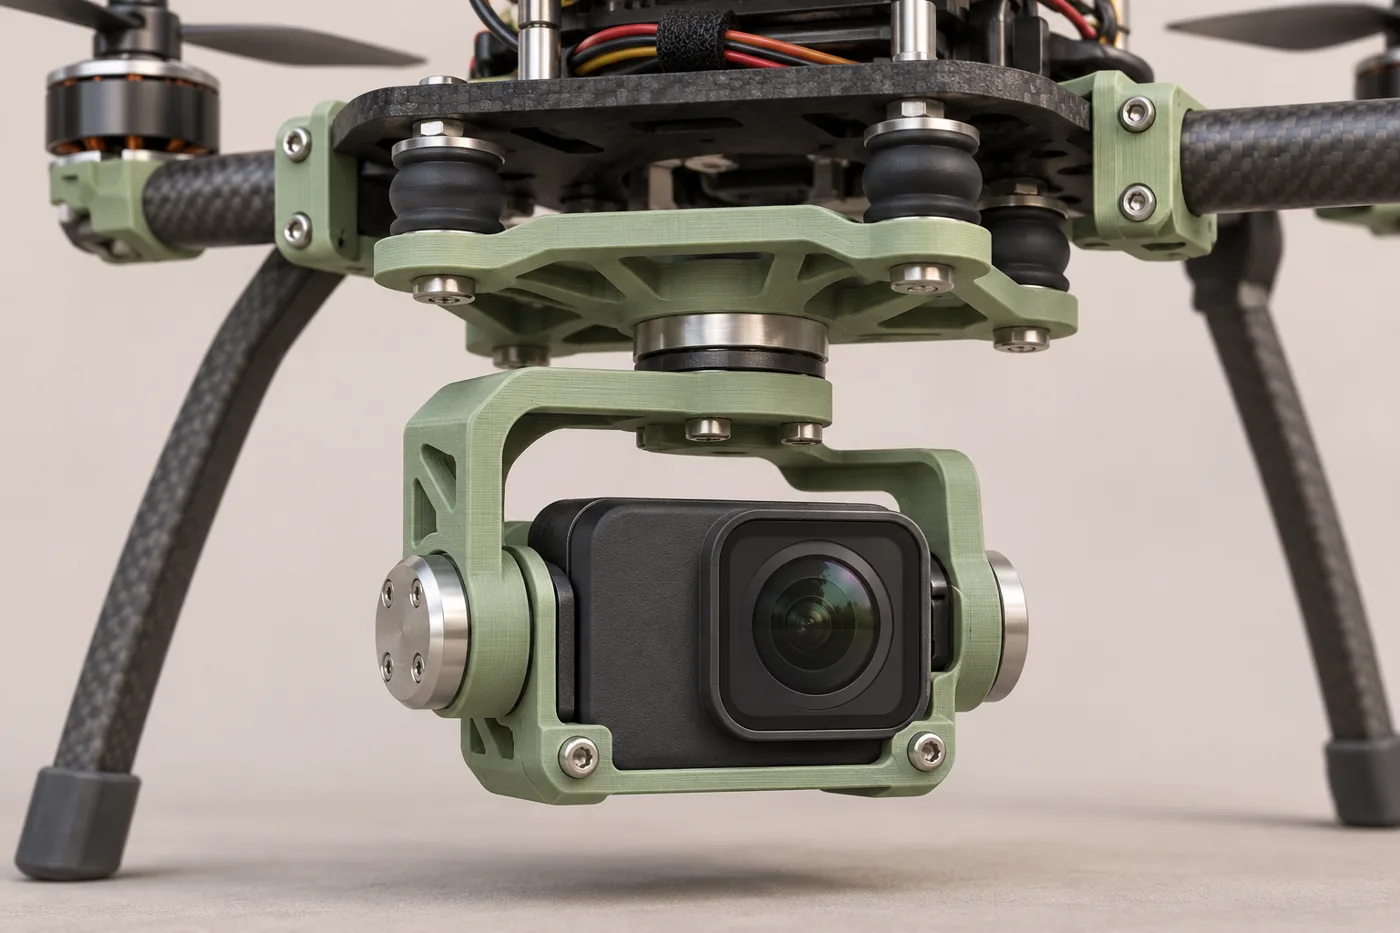
These are concept illustrations created for this portfolio page; they are not photographs or CAD exports of the original club prototype.